 |
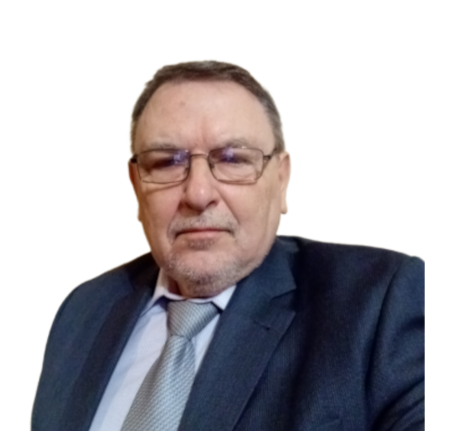
Uspenskyi Valerii
Doctor of Technical Sciences, Associate Professor
Professor, Department of Computer Modeling of Processes and Systems, NTU “KhPI”
|
Research profiles
E-mail: Valerii.Uspenskyi@khpi.edu.ua
Research Profile:
Research activities focus on the development and enhancement of navigation and control systems for mobile objects, such as unmanned aerial vehicles (UAVs) and artificial Earth satellites. Primary emphasis is placed on developing the mathematical framework and algorithms for these systems, providing theoretical validation, improving operational accuracy and reliability, and ensuring information protection against natural and artificial interference. Specific research areas include the calibration of inertial sensors for navigation systems, the implementation of swarm behavior in multicopters, the application of artificial intelligence methods to navigation and control tasks, and the refinement of relative navigation techniques.
Proposed PhD Research Areas
1Development of models and operational methods for a lifting-and-transport mechanism based on a coupled group of quadcopters: designing the mechanism’s frame structure and motion model; developing autonomous control algorithms for the quadcopters within the mechanism; developing and investigating operational scenarios; determining the scope of effective application and practical implementation requirements.
2Development of autonomous control methods for quadcopters operating in a dense swarm: developing swarm motion models and defining onboard equipment requirements; enhancing onboard systems for swarm agents, including through relative navigation methods; developing autonomous control algorithms for swarm quadcopters to execute complex motion patterns, such as murmuration.
3Development of neural network-based error models for inertial sensors to improve the operational accuracy of aircraft inertial systems: implementing inertial navigation algorithms and analyzing the impact of errors on operational accuracy; analyzing and selecting an appropriate neural network architecture for modeling gyroscope and accelerometer errors; developing a test-motion methodology for the inertial unit to train the neural model; evaluating effectiveness and comparing results with standard models.
Research Projects and International Collaboration
1Project Leader, Project BF5803: “Development of methods and algorithms for modeling UAV swarm behavior” (January 2024 – December 2024).
2Project Leader, Project BF5804: “Development of algorithmic support for aircraft navigation and control systems under conditions of interference or incomplete information” (January 2025 – December 2025).
3Lead Researcher, Project EU#3053: “Investigation of thermal influence on errors in orientation systems used in aerospace engineering” (EURIZON FELLOWSHIP PROGRAMME “Remote Research Grants”, 2024–2025).
Selected publications
1Uspenskyi V. B. Avtonomnyi metod dokalibruvannia bezplatformnoi inertsialnoi navihatsiinoi systemy u khodi ekspluatatsii. Bulletin of the National Technical University “KhPI”. Series: Dynamics and Strength of Machines. 2023. No. 1. pp. 3–13. DOI: https://doi.org/10.20998/2078-9130.2023.1.273074 [in Ukrainian].
2Uspenskyi V., Optimal Reconfiguration Planning for Large UAV Groups / V. B. Uspenskyi, N. V. Shyriaieva // 2023 IEEE International Workshop on Technologies for Defense and Security, nov. 2023. https://doi.org/10.1109/TechDefense59795.2023.10380899
3Uspenskyi V. B., Shyriaieva N. V. Optimal Reconfiguration Planning for Large UAV Groups. 2023 IEEE International Workshop on Technologies for Defense and Security (TechDefense). November 2023. DOI: https://doi.org/10.1109/TechDefense59795.2023.10380899
4Uspenskyi V. B. Metod vidnosnoi navihatsii dlia orbitalnykh obiektiv. Bulletin of the National Technical University “KhPI”. Series: Dynamics and Strength of Machines. 2025. No. 1. pp. 96–107. DOI: https://doi.org/10.20998/2078-9130.2025.1.324136 [in Ukrainian].